SG–01
Steering Drive Module Selection Guide
Understand the main inputs used to preselect a steering drive module for underride AMRs, transport robots and other mobile platforms.
Key application inputs
Practical engineering references for selecting and integrating drive, steering, lifting and load-bearing components for AGV and AMR systems.
A suitable mobility component must work within the complete vehicle architecture. Vehicle mass, load distribution, acceleration, floor conditions, mounting envelope, control interface and operating cycle can all affect the final configuration.
These guides are designed to help engineering and purchasing teams identify the information that matters, compare available technical routes and prepare for a more efficient selection discussion.
Start with drive and steering, lifting, wheels or system integration.
Collect the required load, speed, space, duty-cycle and interface information.
Clarify key differences, trade-offs and common selection risks.
Confirm the component direction, interfaces and prototype validation requirements.
Each guide identifies the principal application inputs, selection considerations and integration questions that should be reviewed before confirming a product family or model.
Understand the main inputs used to preselect a steering drive module for underride AMRs, transport robots and other mobile platforms.
Review the relationship between vehicle mass, wheel load, drive torque and differential steering performance for medium- and heavy-duty mobile platforms.
Compare ball screw, trapezoidal screw and hydraulic lifting solutions based on load, stroke, speed, synchronisation, installation and safety requirements.
Evaluate load-bearing wheels, swivel casters, omni wheels and Mecanum wheels according to load, floor, motion behaviour, material and operating conditions.
Complete data is not always available at the beginning of a project. However, the following inputs help reduce assumptions, shorten communication and improve the quality of the initial recommendation.
Get Selection SupportGross mass, payload range, centre of gravity and expected load distribution.
Maximum speed, acceleration, turning behaviour, gradients and positioning requirements.
Available height, footprint, mounting direction, interface dimensions and service access.
Working hours, travel cycle, start-stop frequency, continuous operating periods and peak conditions.
Floor material, joints, contamination, temperature, humidity, gradients and indoor or outdoor use.
System voltage, motor type, brake requirements, available current and power limitations.
Encoder type, communication requirements, positioning feedback and controller compatibility.
Prototype quantity, test conditions, acceptance criteria, project timing and expected series demand.
Concise technical explanations for engineering, procurement and project teams evaluating AGV and AMR mobility components.
A practical overview of the vehicle and application data required to evaluate load capacity, traction, speed, installation, electrical configuration and operating conditions.
Review the key inputs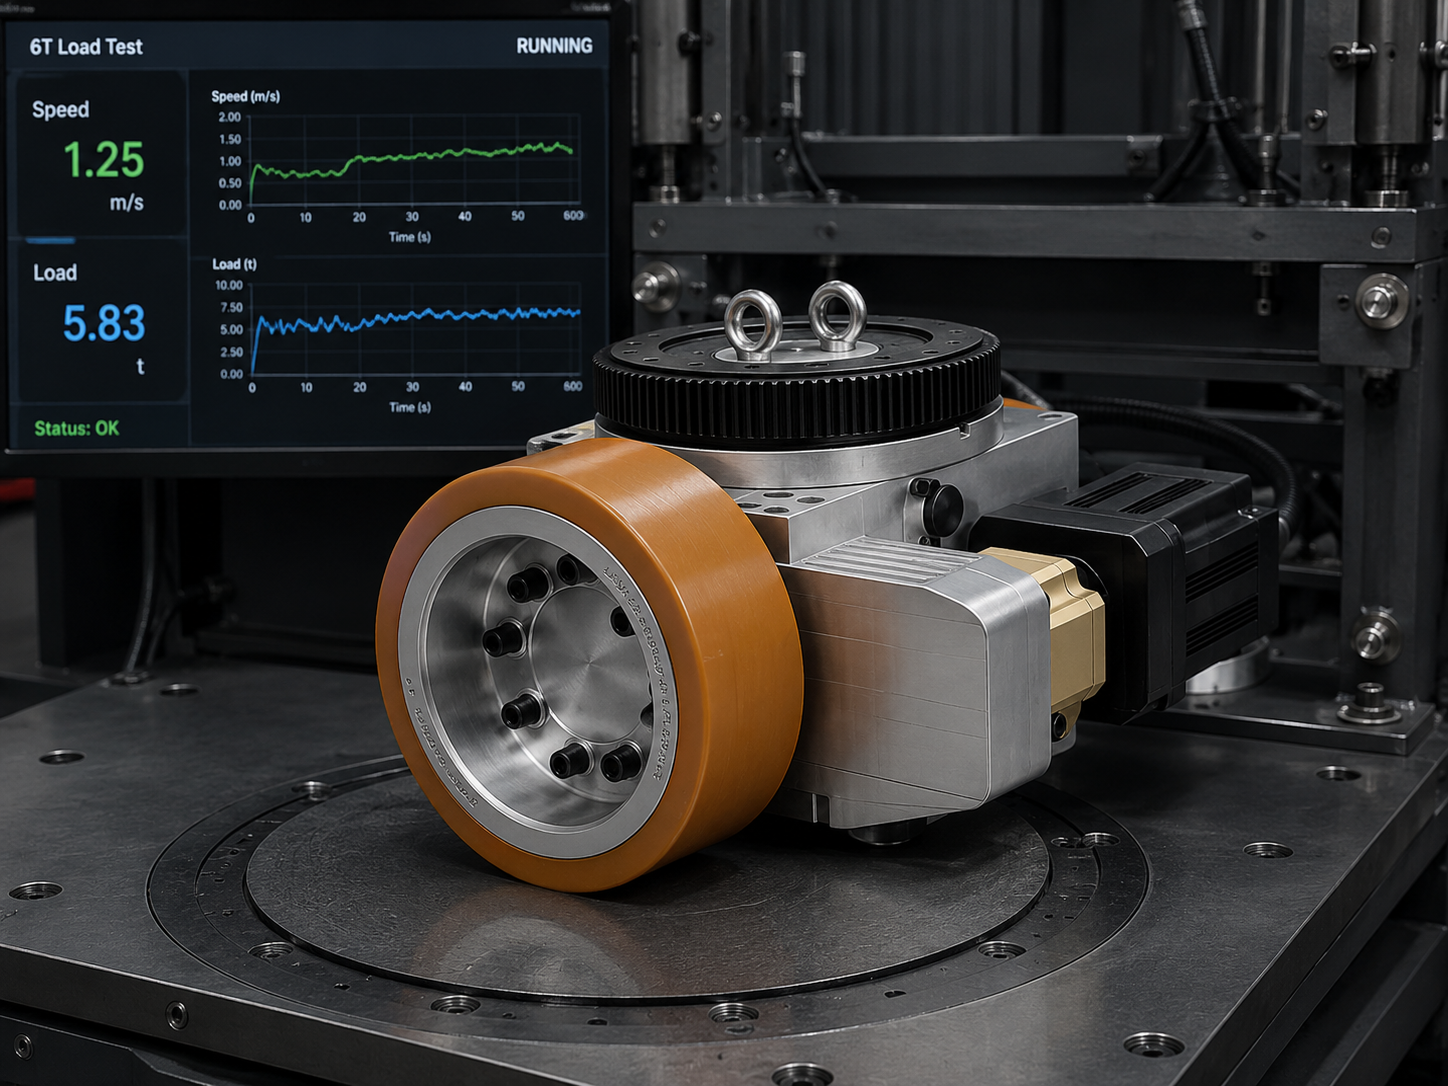
Compare the two mobility architectures in terms of manoeuvrability, installation space, control strategy, load distribution and typical application requirements.
Discuss the applicationUnderstand how lifting load, stroke, speed, positioning, self-locking behaviour, synchronisation and maintenance influence the choice of lifting technology.
Discuss the applicationLearn why load capacity alone does not determine drive performance, and how friction, acceleration, wheel material, gradients and load distribution influence traction.
Discuss the applicationThe guides and articles provide preliminary technical direction. Final specifications should be reviewed using the actual project load, motion, installation, control, environmental and validation requirements.
Share your load, motion, installation space, duty cycle and interface requirements. JY ROBOT will help review the application, identify a suitable component direction and support prototype integration.