Mecanum Wheel Drive Modules for AGV/AMR
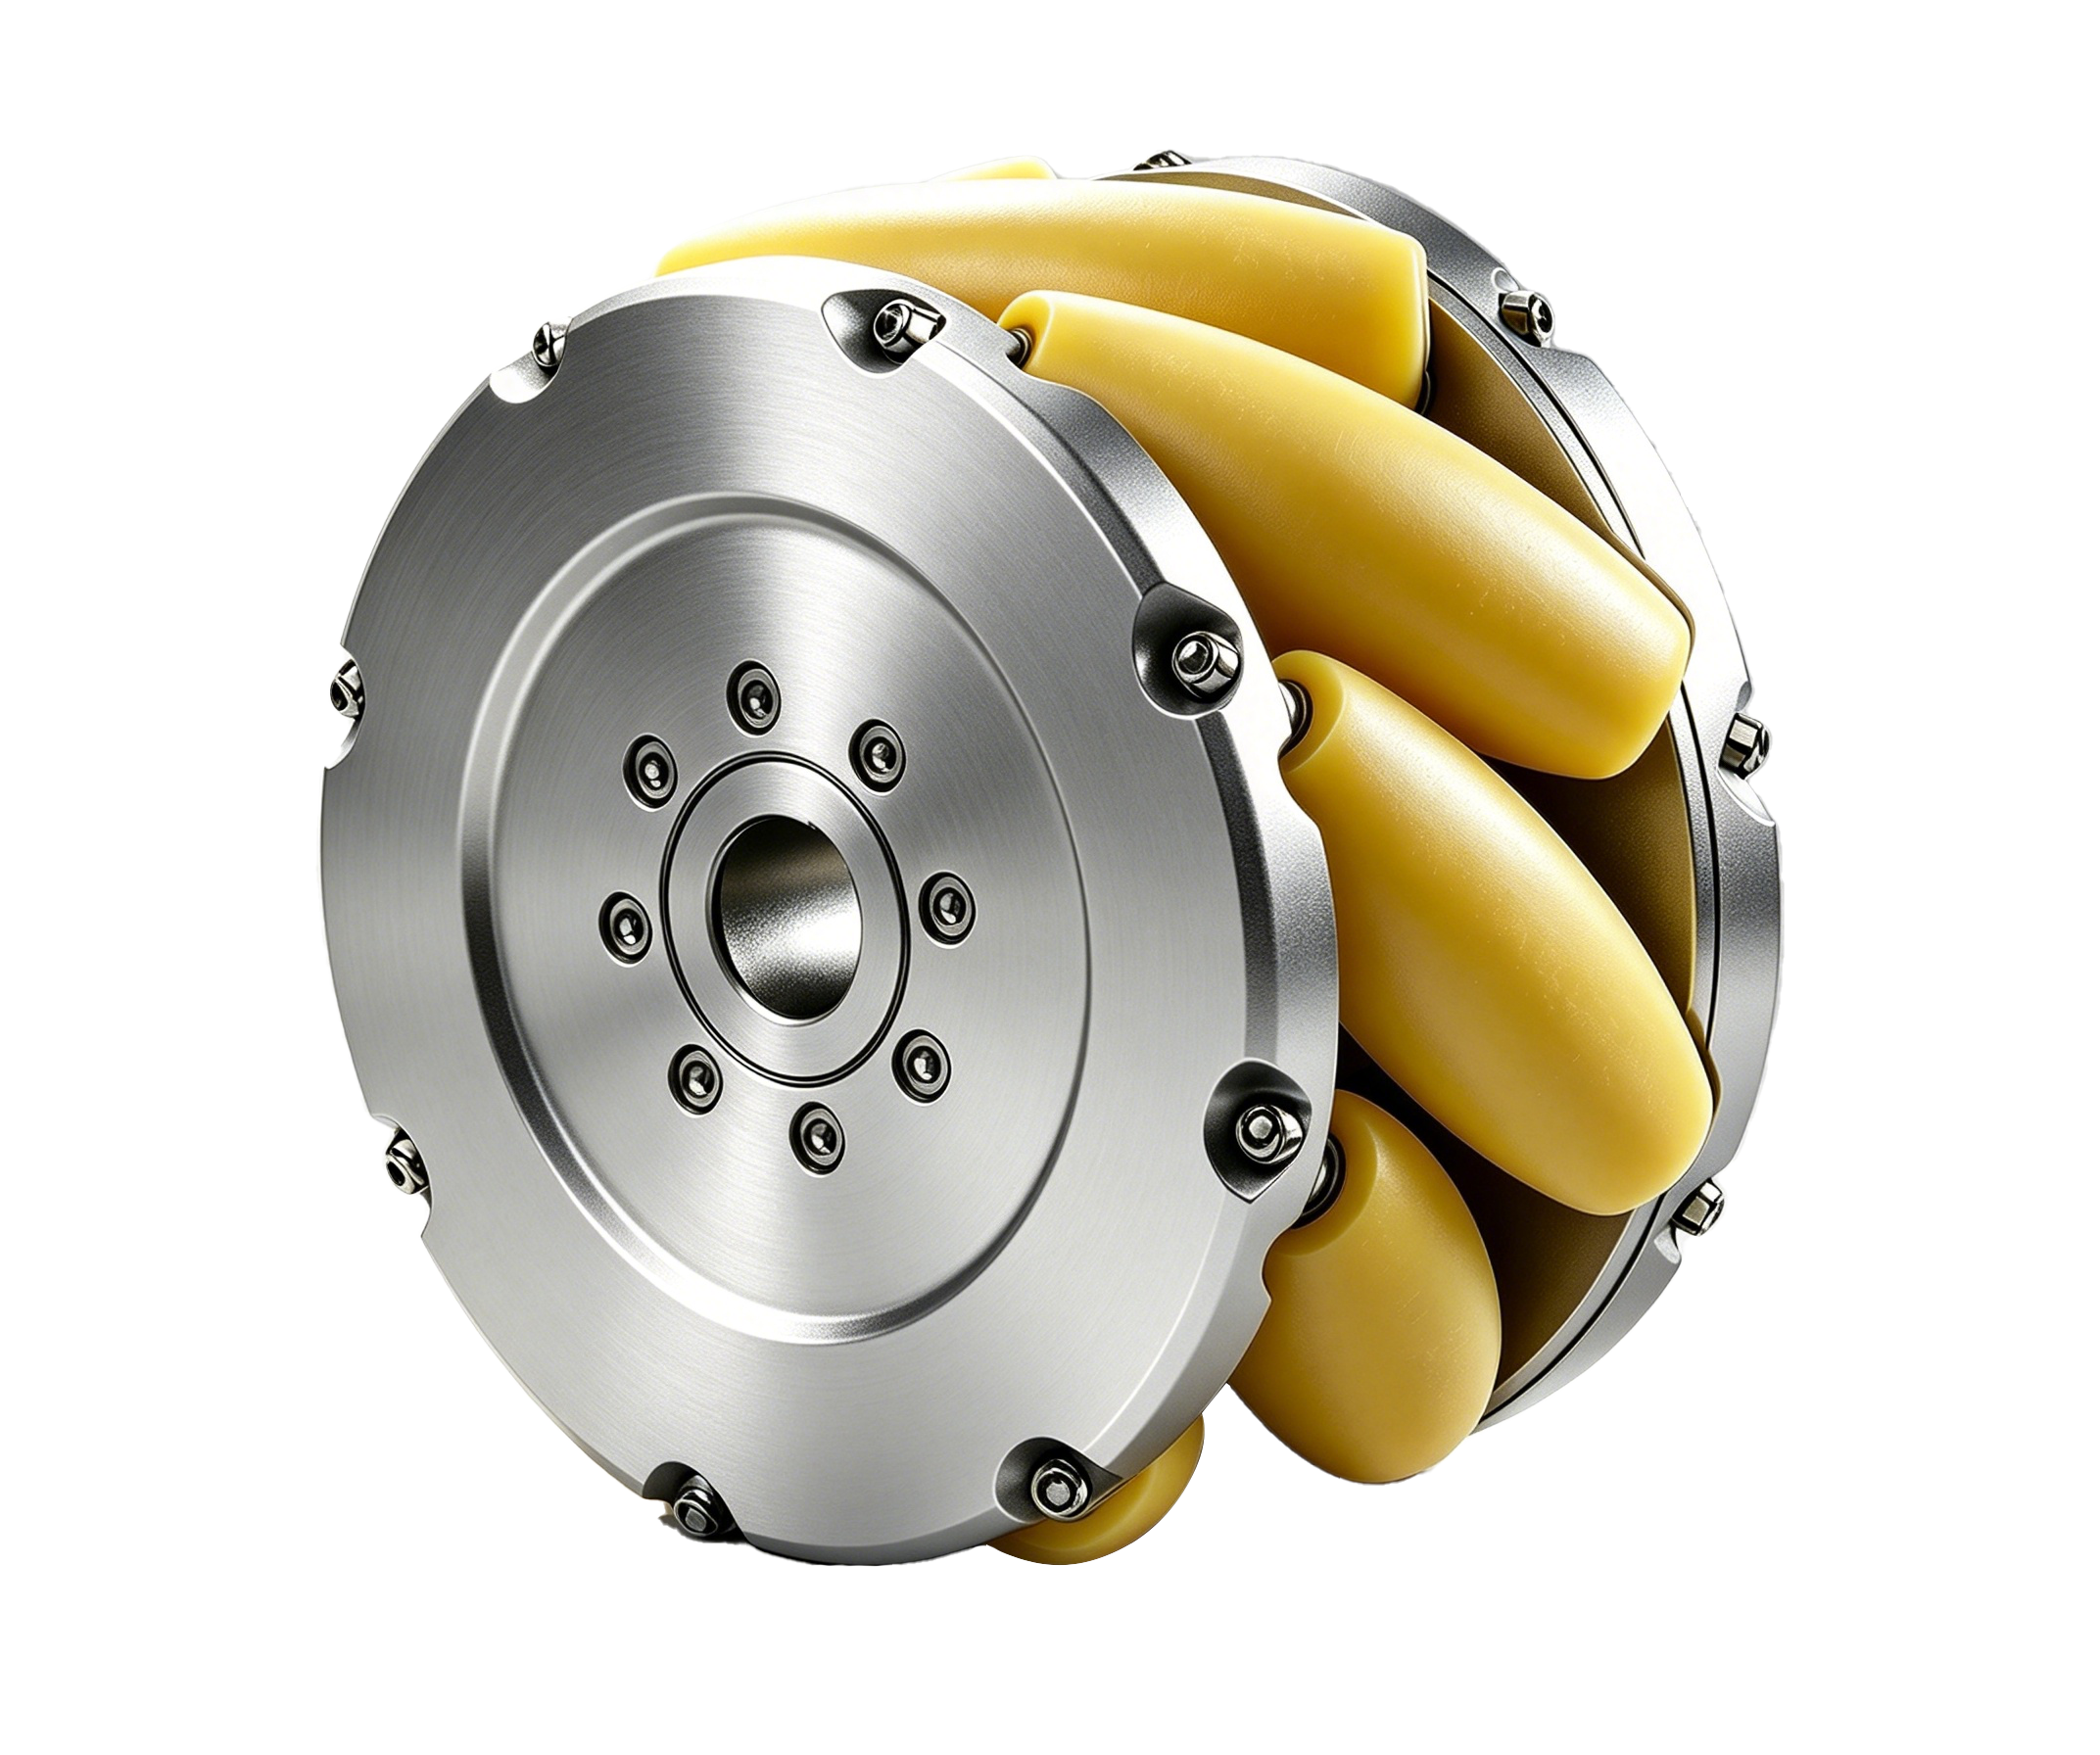
Integrated Mecanum wheel drive modules for AGV and AMR platforms, supporting forward, lateral, diagonal and in-place rotational movement.
Mecanum Wheel Drive for AGV and AMR Platforms
A Mecanum wheel drive allows an AGV or AMR to move forward, backward, sideways, diagonally and rotate in place by controlling multiple independently driven Mecanum wheels. This omnidirectional motion is useful where aisle width, docking position and maneuvering space are limited.
JY Robot's JP-MW integrated Mecanum drive module combines the wheel, drive structure and mechanical transmission into a compact module for AGV, AMR and other omnidirectional mobile robot platforms. The current product family covers Mecanum wheel diameters from approximately 205 mm to 555 mm.
When to Use a Mecanum Wheel Drive Module
- Sideways movement: useful when the vehicle must align with racks, workstations or transfer equipment without turning the complete chassis.
- Tight-space maneuvering: supports diagonal motion and in-place rotation in restricted industrial areas.
- Flexible docking: allows position correction in both longitudinal and lateral directions.
- Omnidirectional mobile robots: suitable for platforms that require independent wheel-speed control for multi-directional travel.
Mecanum Wheel vs Omni Wheel
Mecanum wheels use angled rollers around the wheel circumference to generate longitudinal and lateral force components. Omni wheels use rollers arranged around the wheel body with a different kinematic layout. The preferred architecture depends on chassis geometry, load distribution, floor condition, required motion direction and control strategy.
For a detailed engineering comparison, see our Mecanum wheel vs omni wheel guide for AGV and AMR. For integrated omni-wheel assemblies, see our omni wheel drive modules.
How to Select a Mecanum Drive Module
Selection should start from vehicle mass, payload, number of driven wheels, wheel load, target speed, required acceleration, floor condition, wheel diameter and available installation space. Mecanum-wheel systems also require coordinated speed control between multiple drive units, so controller architecture and feedback requirements should be confirmed before finalizing the mechanical design.
If your platform does not require omnidirectional travel, compare Mecanum drive with conventional AGV drive wheels and drive modules, including drive-steering and differential-drive architectures.
For engineering selection support, provide vehicle self-weight, payload, wheel quantity, expected load per wheel, target speed, floor condition, battery voltage, control interface, required motion directions and available installation envelope.
Need help choosing a configuration?
Share your platform load, target speed, installation space and control requirements. JY Robot can help narrow down the suitable product family and model.