Product Overview
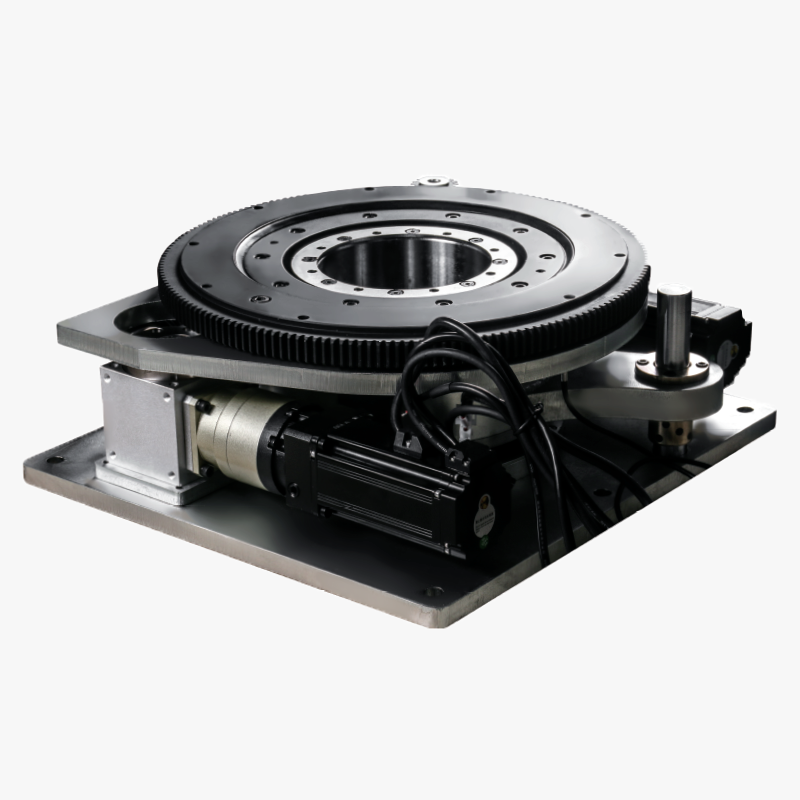
JY ROBOT ball screw lifting modules integrate electric lifting, ball-screw transmission, platform rotation, position feedback and communication control into a compact assembly. They are designed for load lifting, rotation and workstation docking in AGV and AMR applications.
The series covers load capacities from 200 to 2,000 kg. The standard lifting speed is 8.3 mm/s, while the lifting stroke can be configured from 50 to 100 mm according to project requirements. Both the lifting and rotary sections use servo motors and absolute encoders to provide feedback for position monitoring and motion control.
RS-485, CANopen and EtherCAT interfaces are available. Model and configuration selection can be matched to the load, stroke, installation envelope, lifting frequency, rotation requirements and control architecture.
Key Features
Ball Screw Lifting Transmission
The ball screw converts motor rotation into controlled linear lifting motion.
Integrated Lifting and Rotation
Load lifting and platform rotation are integrated into one module, reducing the number of separate chassis components.
Dual-Axis Position Feedback
Absolute encoders on the lifting and rotary axes provide feedback for position monitoring and motion control.
Multiple Communication Interfaces
RS-485, CANopen and EtherCAT are supported, with configurable lifting stroke and load capacity.
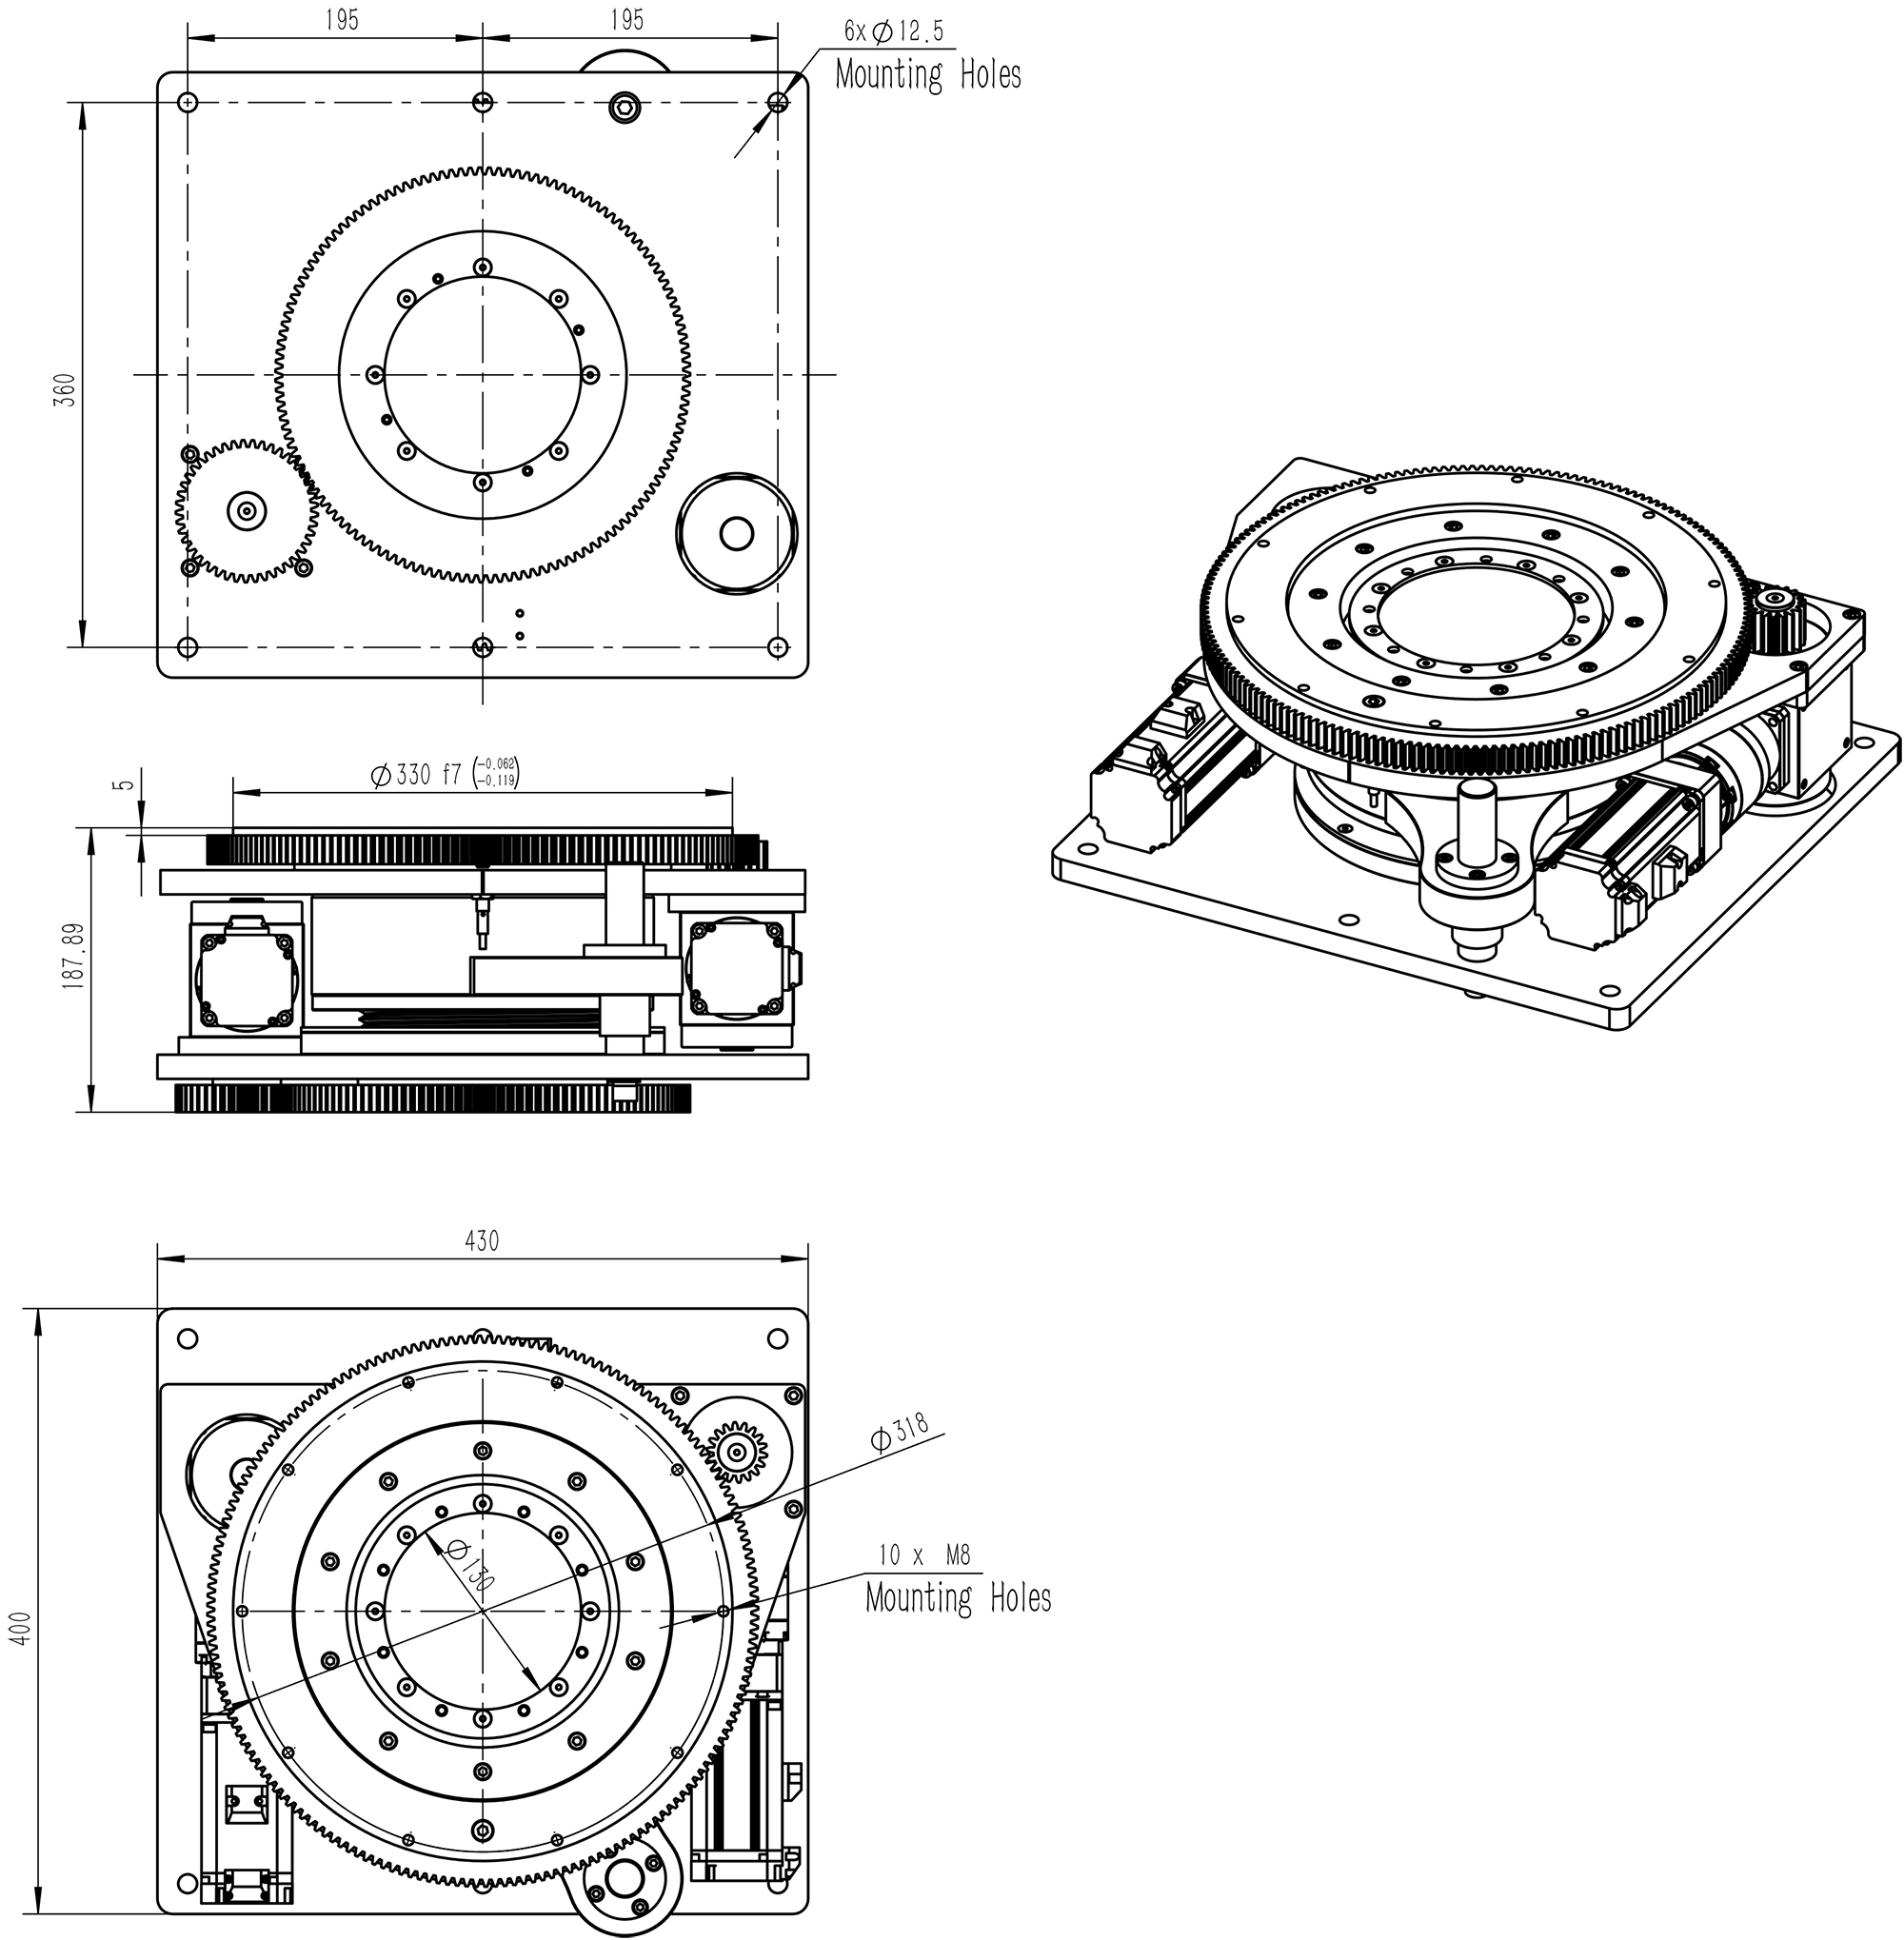
Product Drawings
 Click to enlarge
Product Specifications
| Category | Parameter | JY-LIFT-L200-M200-S60 | JY-LIFT-L500-M400-S60 | JY-LIFT-L1000-M600-S60 | JY-LIFT-L1500-M750-S60 | JY-LIFT-L2000-M1000-S60 |
| performance metrics | parameter | |||||
| Lifting System | Motor Type | Servo Motor | Servo Motor | Servo Motor | Servo Motor | Servo Motor |
Lifting Motor Power(W) | 200 | 400 | 600 | 750 | 1000 | |
| Rated Voltage (VDC) | 48 | 48 | 48 | 48 | 48 | |
| Rated Current (A) | 5.7 | 10.6 | 18 | 19 | 25.8 | |
| Rated Torque (N·m) | 0.64 | 1.27 | 1.91 | 2.3875 | 3.183333333 | |
| Rated Speed (rpm) | 3000 | 3000 | 3000 | 3000 | 3000 | |
| Lifting Encoder Type | Absolute Encoder | Absolute Encoder | Absolute Encoder | Absolute Encoder | Absolute Encoder | |
| Rotary System | Motor Type | Servo Motor | Servo Motor | Servo Motor | Servo Motor | Servo Motor |
| Rotary Motor Power (W) | 200 | 400 | 600 | 750 | 1000 | |
| Rated Voltage (VDC) | 48 | 48 | 48 | 48 | 48 | |
| Rated Current (A) | 5.7 | 10.6 | 18 | 19 | 25.8 | |
| Rated Torque (N·m) | 0.64 | 1.27 | 1.91 | 2.3875 | 3.183333333 | |
| Rated Speed (rpm) | 3000 | 3000 | 3000 | 3000 | 3000 | |
| Rotary Encoder Type | Absolute Encoder | Absolute Encoder | Absolute Encoder | Absolute Encoder | Absolute Encoder | |
| Rotary Gear Ratio | 200:1 | 200:1 | 200:1 | 200:1 | 200:1 | |
| Rotation Speed (°/s) | 90 | 90 | 90 | 90 | 90 | |
| Lifting Transmission | Transmission Type | Ball Screw | Ball Screw | Ball Screw | Ball Screw | Ball Screw |
| Lifting Stroke (mm) | 50–100, Customisable | 50–100, Customisable | 50–100, Customisable | 50–100, Customisable | 50–100, Customisable | |
| Screw Lead (mm) | 10 | 10 | 10 | 10 | 10 | |
| Transmission Ratio | 60:1 | 60:1 | 60:1 | 60:1 | 60:1 | |
| Lifting Speed (mm/s) | 8.3 | 8.3 | 8.3 | 8.3 | 8.3 | |
| Sensors | Proximity Sensor Type | PNP | PNP | PNP | PNP | PNP |
| Sensor Rated Voltage (VDC) | 24 | 24 | 24 | 24 | 24 | |
| Performance | Communication Interfaces | RS-485 / CANopen / EtherCAT | RS-485 / CANopen / EtherCAT | RS-485 / CANopen / EtherCAT | RS-485 / CANopen / EtherCAT | RS-485 / CANopen / EtherCAT |
| Load Capacity (kg) | 200 | 500 | 1000 | 1500 | 2000 | |
| Net Weight (kg) | 70 | 80 | 85 | 110 | 200 | |
Project Supply & Customization
JY Robot supports AGV and AMR builders with ball screw lifting modules for prototype development, pilot builds and series supply. Selection can be reviewed according to lifting load, stroke, installation height, lifting frequency, rotation requirement and control architecture.
Stroke, mounting interface and control configuration can be matched to project requirements where applicable. CAD files and engineering review are available to confirm integration before prototype or production ordering.