At a Glance
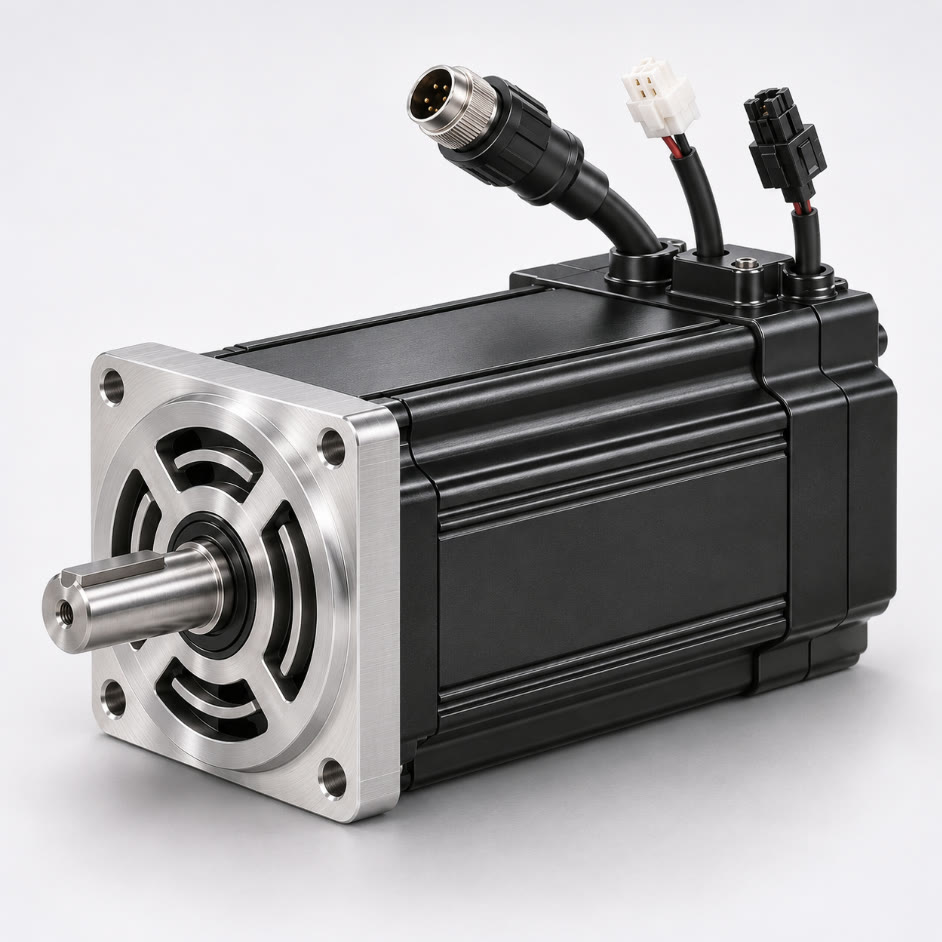
A 48 V low-voltage servo motor for battery-powered AGVs and AMRs, with a multi-turn absolute encoder and 3× overload.
| Rated power | 200–1,500 W |
|---|---|
| Flange | 60 mm or 80 mm |
| Rated torque | 0.64–4.77 N·m (peak up to 14.31 N·m) |
| Encoder | multi-turn magnetic absolute, no homing after power-up |
| Matching drives | JY-SD125, JY-SD135, JY-SD145 with CANopen or EtherCAT |
| Manufacturer | JY Robot, China (R&D in Nanjing, production in Zhejiang) |
Also consider: 130-flange motors for 1.5–3 kW; compact 400 W 48 V DC servo motor.
Model Pages
Each configuration in this series has its own specification page:
Product Overview
JY-SM 60/80 servo motors are designed for battery-powered mobile robots. They run directly on a 48 V DC bus, fit compact 60 mm and 80 mm flanges and deliver 3× overload for start-up and ramp peaks.
Eight standard models cover 200–1,500 W and 0.64–4.77 N·m rated torque (up to 14.31 N·m peak). A multi-turn magnetic absolute encoder keeps the position through power-off, so the vehicle needs no homing after power-up.
Typical uses are drive-steering units, differential drives, lifting mechanisms and four-way shuttles. A holding brake is optional (suffix B), and each motor has a matching 48 V servo drive with CANopen or EtherCAT.
Key Features
Low-voltage DC
Runs directly on 48 V batteries.Multi-turn absolute
No homing after power-up.3× overload
Covers start-up and ramp peaks.Brake option
Suffix B = with holding brake.Product Specifications
| Category | Parameter | JY-SM60-020A | JY-SM60-040A | JY-SM60-060A | JY-SM80-040A | JY-SM80-075A | JY-SM80-100A | JY-SM80-120A | JY-SM80-150A |
| Motor | Flange (mm) | 60 | 60 | 60 | 80 | 80 | 80 | 80 | 80 |
| Rated power (W) | 200 | 400 | 600 | 400 | 750 | 1,000 | 1,200 | 1,500 | |
| Rated voltage (VDC) | 48 | ||||||||
| Torque | Rated torque (N·m) | 0.64 | 1.27 | 1.91 | 1.27 | 2.39 | 3.18 | 3.82 | 4.77 |
| Peak torque (N·m) | 1.92 | 3.81 | 5.73 | 3.81 | 7.17 | 9.54 | 11.46 | 14.31 | |
| Speed | Rated / max. speed (rpm) | 3000 / 4000 | 3000 / 3500 | 3000 / 3500 | 3000 / 3500 | 3000 / 3500 | 3000 / 3500 | 3000 / 3500 | 3000 / 4000 |
| Current | Rated current (Arms) | 5.9 | 10 | 15 | 10.3 | 18.1 | 24 | 29.2 | 36 |
| Peak current (Arms) | 18.9 | 32 | 48 | 33 | 56 | 73 | 87.5 | 110 | |
| Mechanical | Radial / axial load (N) | 115 / 70 | 115 / 70 | 115 / 70 | 235 / 90 | 270 / 90 | 270 / 90 | 270 / 90 | 270 / 90 |
| Holding brake | Optional (suffix B) | ||||||||
| Feedback | Encoder | Multi-turn magnetic absolute | |||||||
| Matching drive | JY-SD125 | JY-SD125 | JY-SD125 | JY-SD125 | JY-SD135 | JY-SD135 | JY-SD145 | JY-SD145 | |
Matching 48 V low-voltage servo drives
Suffix C = CANopen, E = EtherCAT, L = RS485 + pulse.
| Drive | Motor power (flange) | Communication | DC bus |
| JY-SD125 | 200–600 W (60) · 400 W (80) | CANopen / EtherCAT | 48 VDC |
| JY-SD135 | 750–1,000 W (80) | CANopen / EtherCAT | 48 VDC |
| JY-SD145 | 1,200–1,500 W (80) | CANopen / EtherCAT | 48 VDC |
Matching 48 V low-voltage servo drives
Suffix C = CANopen, E = EtherCAT, L = RS485 + pulse.
| Drive | Motor power (flange) | Communication | DC bus |
| JY-SD125 | 200–600 W (60) · 400 W (80) | CANopen / EtherCAT | 48 VDC |
| JY-SD135 | 750–1,000 W (80) | CANopen / EtherCAT | 48 VDC |
| JY-SD145 | 1,200–1,500 W (80) | CANopen / EtherCAT | 48 VDC |