Product Overview
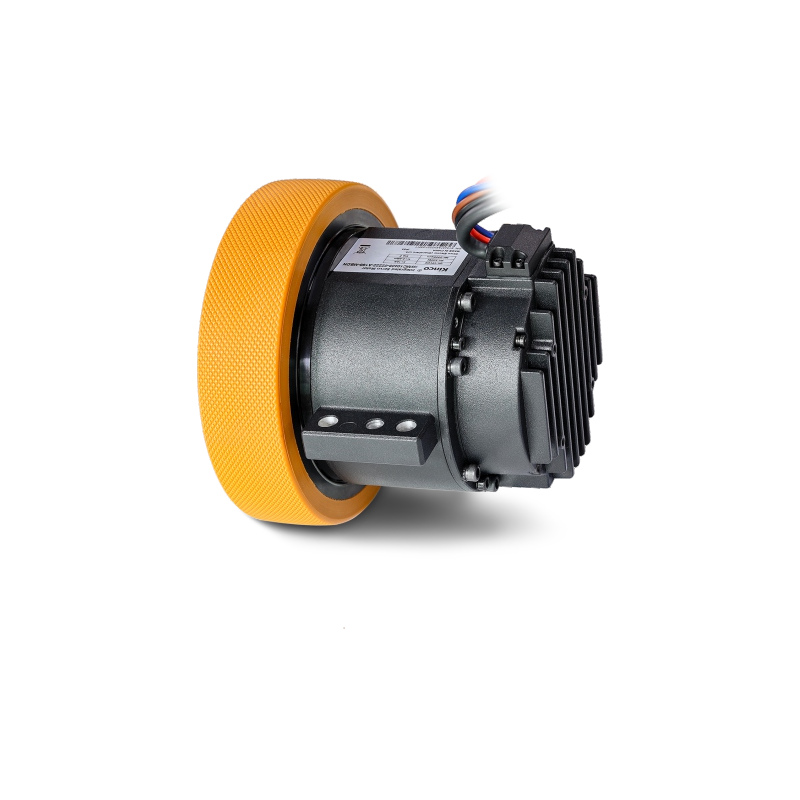
ISW STO series integrated servo wheel module combines the drive, motor, gearbox and wheel into one compact unit. It is suitable for various types of mobile robots with load capacities from 0.6 t to 2 t.
The series uses a fixed-cable design and is available with Ø165 mm and Ø180 mm antistatic polyurethane wheels. It covers rated torque from 22 to 75 N·m, maximum torque from 66 to 200 N·m, and rated speed from 125 to 227 rpm.
The drive uses separate drive-power and logic-power supplies and supports dual-channel Safe Torque Off (STO), dual encoder-signal outputs, Modbus RTU and standard CANopen communication.
Key Features
Four-in-One Integration
The drive, motor, gearbox and wheel are integrated into a compact unit, reducing the space required inside the vehicle and simplifying vehicle assembly.
STO Functional Safety Interface
Two STO inputs can be connected to a safety controller, safety switch or safety sensor to provide the Safe Torque Off function.
Dual Encoder-Signal Outputs
Two isolated RS485 differential ABZ encoder outputs are provided for vehicle control and status feedback.
High Precision and Low Backlash
A low-backlash reduction mechanism and high-precision mounting structure help improve positioning accuracy and operating smoothness.
High Reliability and Compatibility
Only power and communication connections are required externally. The module offers strong interference resistance and is compatible with Kinco standard product systems.
Easy Maintenance
A complete servo wheel module from a single supplier simplifies selection, maintenance and after-sales management. Product documentation indicates compliance with CE, UL and functional-safety requirements.
Product Drawings
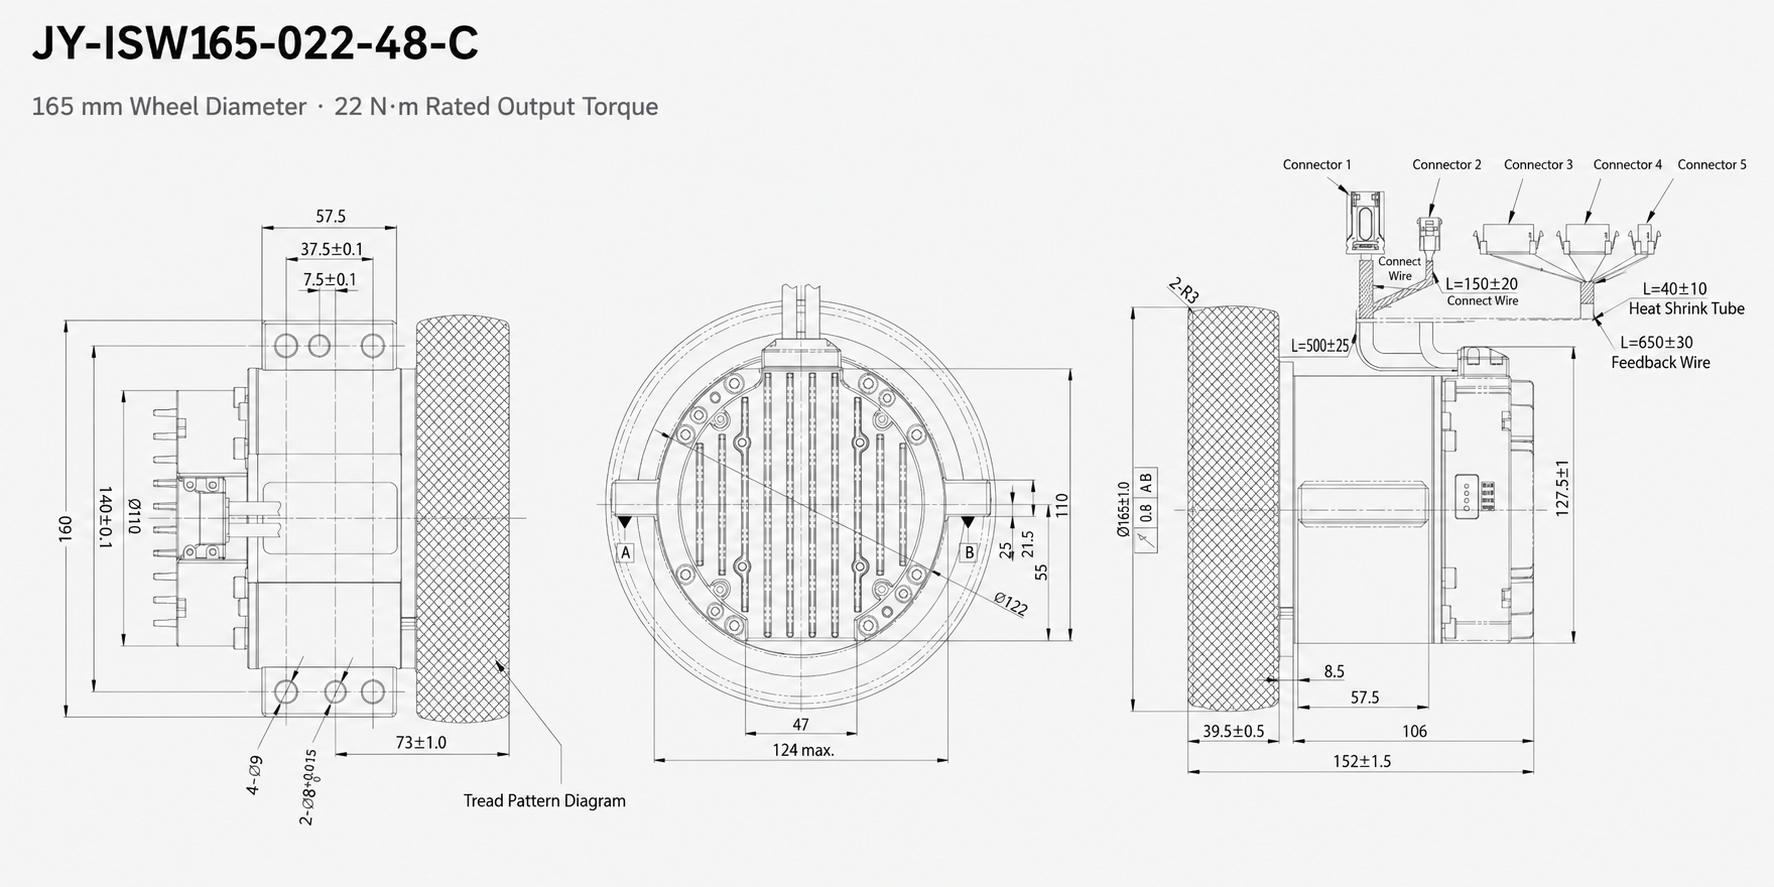 Click to enlarge
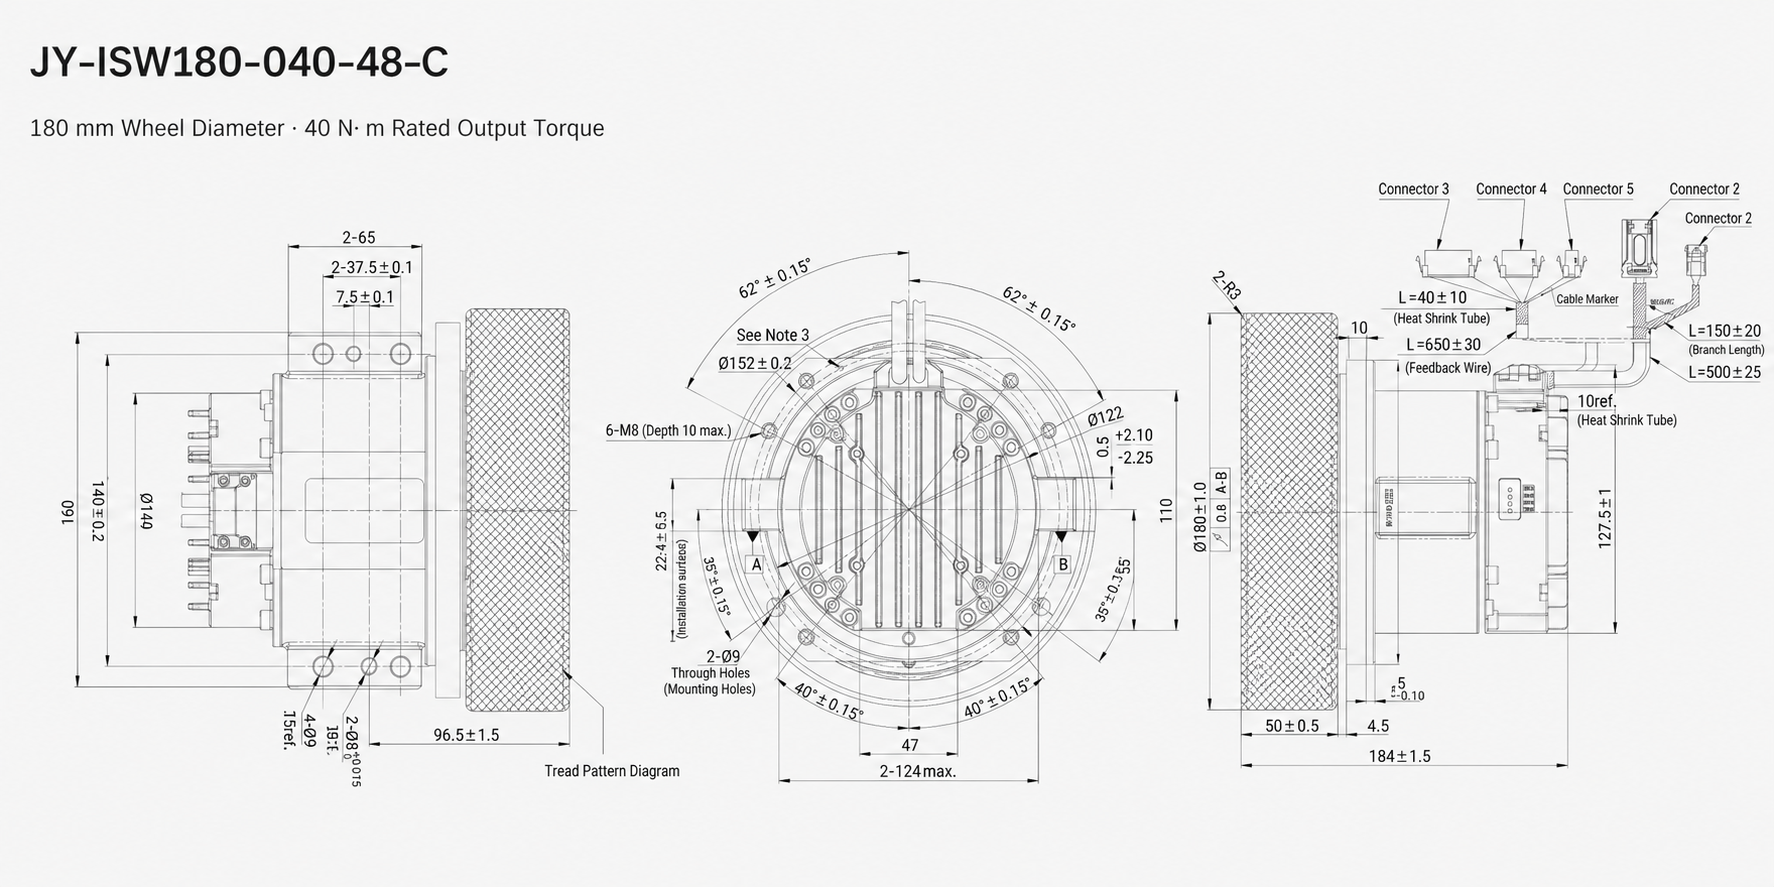 Click to enlarge
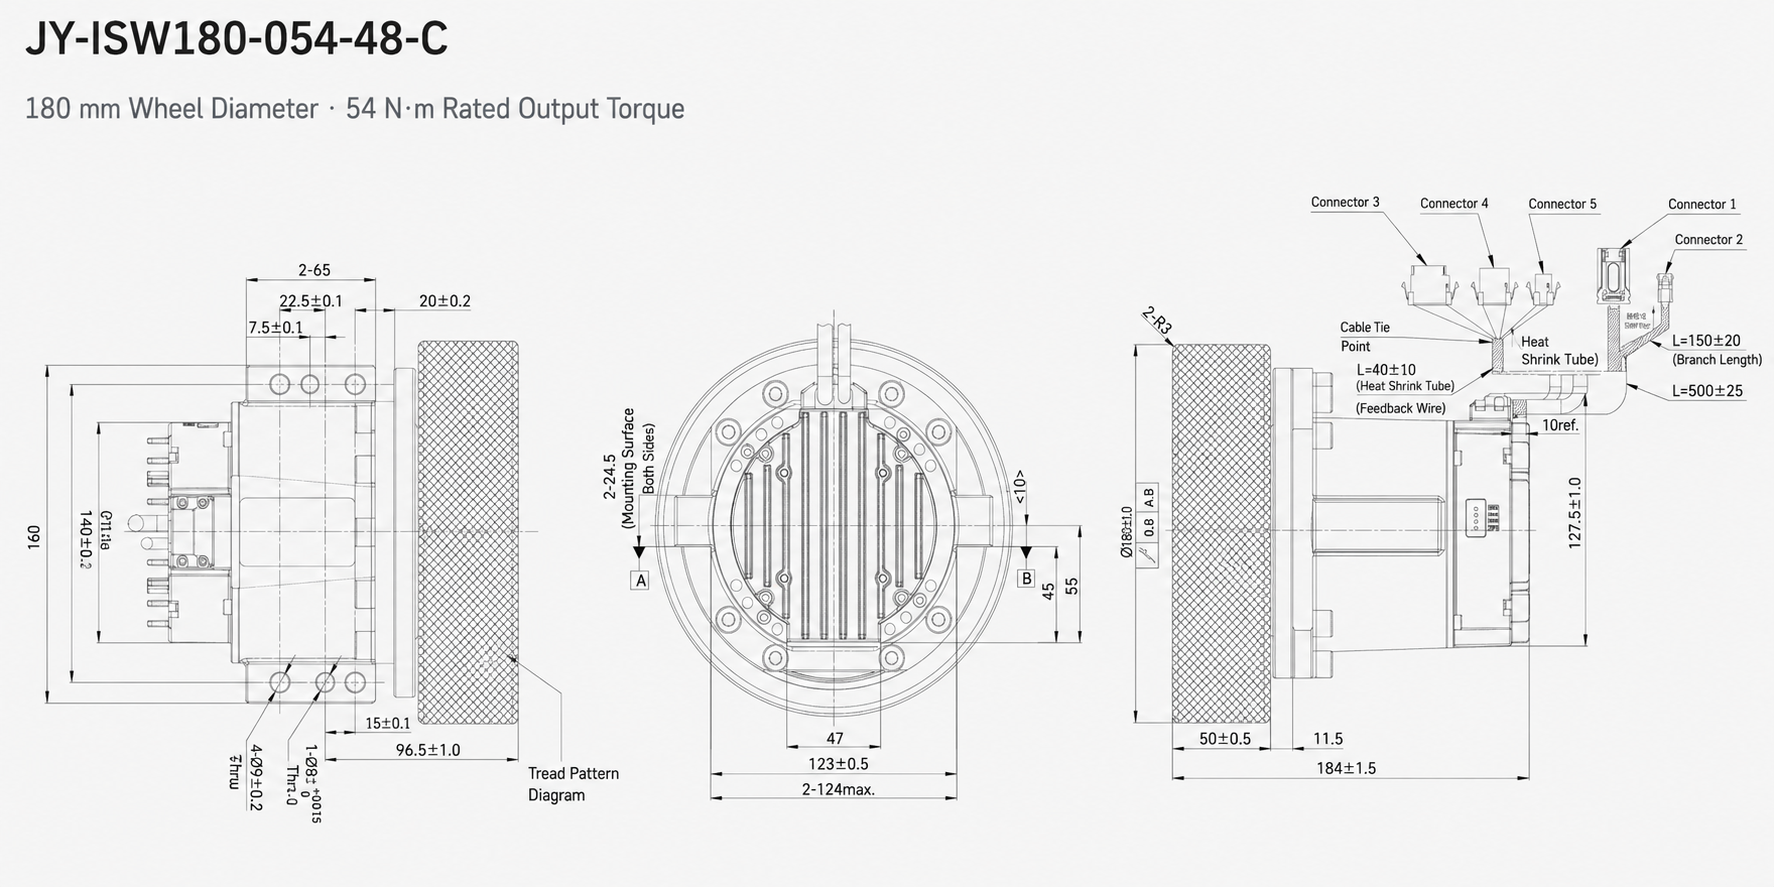 Click to enlarge
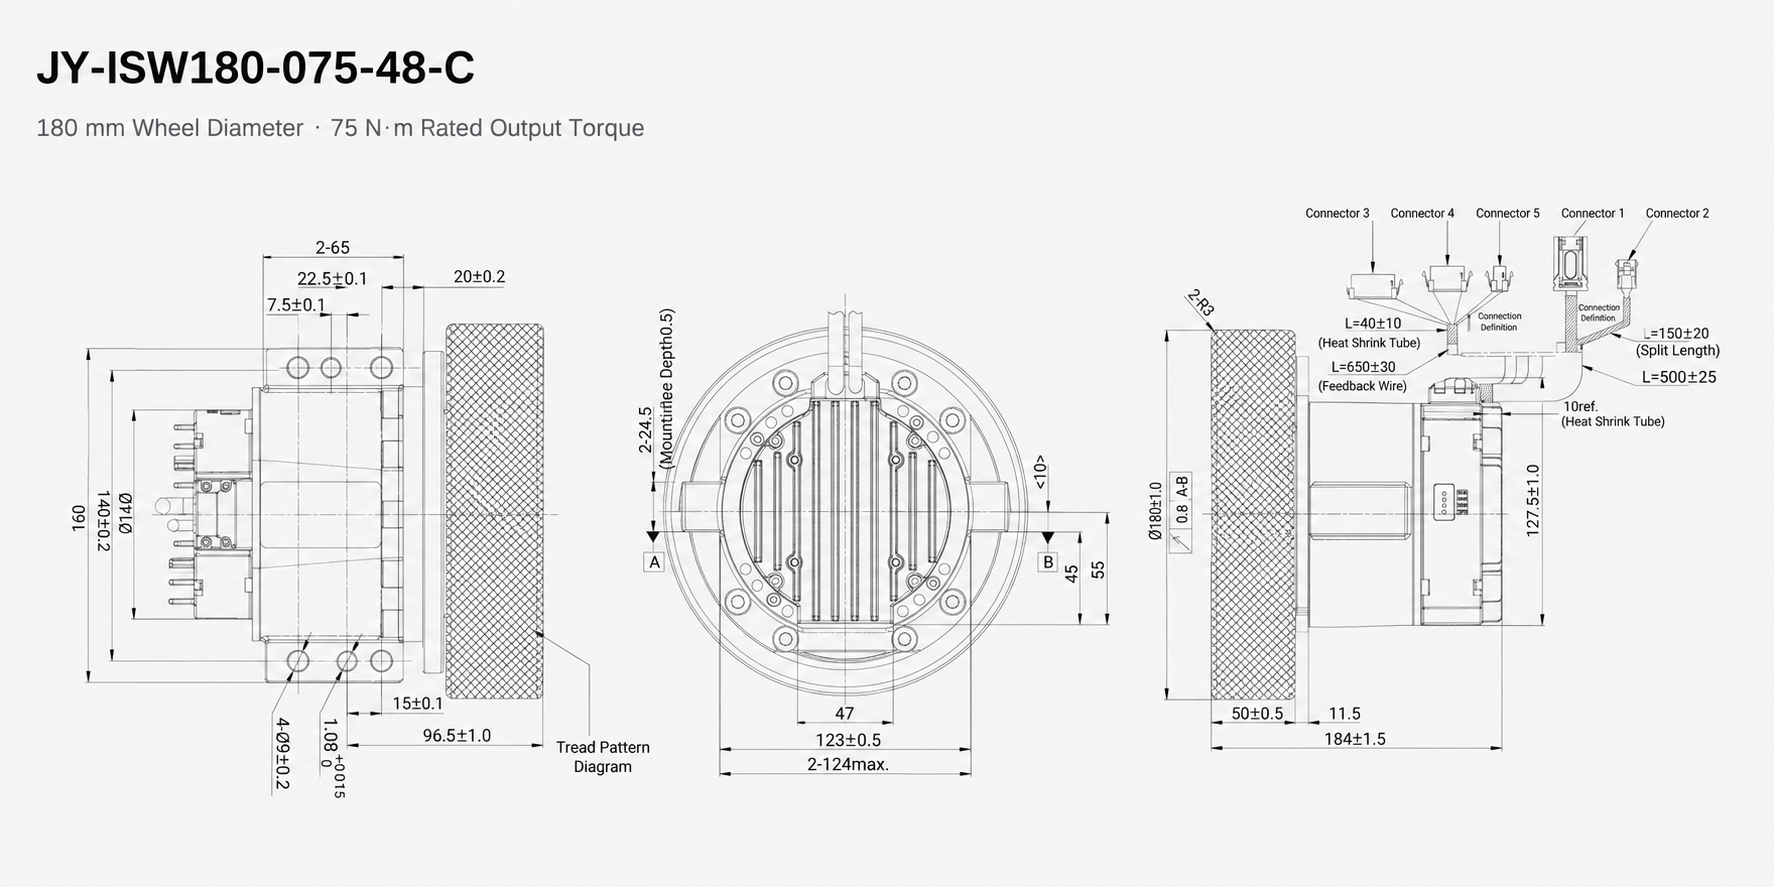 Click to enlarge
Product Specifications
| Category | Product Model | JY-ISW165-022-48-C | JY-ISW180-040-48-C | JY-ISW180-054-48-C | JY-ISW180-075-48-C |
| Parameter | Specifications | ||||
| Power Supply | Drive Power Supply (VDC) | Rated 48 V (24-60 V) | |||
| Logic Power Supply (VDC) | 24 V, 1 A | ||||
| Motor | Rated Power Pn (W) | 530 | 1050 | 1050 | 1050 |
| Rated Torque Ts (N·m) | 2.53 | 4 | 4 | 4 | |
| Rated Speed Nn (rpm) | 2000 | 2500 | 2500 | 2500 | |
| Rated Current In (Arms) | 12.5 | 25 | 25 | 25 | |
| Maximum Current Im (Arms) | 40 | 69 | 69 | 69 | |
| Brake | Brake Holding Torque (N·m) | 4 | 4 | 4 | 4 |
| Complete Unit | Gear Ratio | 9 | 11 | 15 | 20 |
| Rated Torque Ts (N·m) | 22 | 40 | 54 | 75 | |
| Rated Speed Nn (rpm) | 222 | 227 | 167 | 125 | |
| Maximum Torque Tm (N·m) | 66 | 99 | 150 | 200 | |
| Maximum Speed (rpm) | 290 | 263 | 193 | 145 | |
| Maximum Radial Load (N) | 3000 | 7000 | 7000 | 7000 | |
| Maximum Axial Load (N) | 1000 | 1500 | 1500 | 1500 | |
| Wheel | Wheel Diameter (mm) | 165 | 180 | 180 | 180 |
| Wheel Width (mm) | 39.5 | 50 | 50 | 50 | |
| Wheel Material | Antistatic polyurethane | ||||
| Wheel Hardness | 85A±2 | 93A±2 | 93A±2 | 93A±2 | |
| Operation & Braking | Dynamic Braking | External braking resistor | |||
| Dynamic Braking Activation Voltage | 63 VDC ±2 V, adjustable | ||||
| Overvoltage Alarm Threshold | 68 VDC ±2 V | ||||
| Undervoltage Alarm Threshold | 18 VDC ±2 V | ||||
| Cooling Method | Natural cooling | ||||
| Duty Cycle | S3, 60%, 10 min | S3, 40%, 10 min | S3, 40%, 10 min | S3, 40%, 10 min | |
| Cable Type | Fixed cable | ||||
| Functions & Interfaces | Digital Input Specification | 2 DI channels with common COMI; high level: 12.5-30 VDC; low level: 0-5 VDC; maximum frequency: 1 kHz; minimum turn-on voltage: <11 V; maximum turn-off voltage: >5 V; maximum input voltage: 30 V. | |||
| Digital Input Functions | Freely assignable, including drive enable, error reset, operating-mode control, speed-loop proportional control, positive/negative limit, home signal, command reversal, internal speed-segment control, internal position-segment control, emergency stop, start homing, command activation, electronic gear-ratio switching and gain switching. | ||||
| Digital Output Specification | 1 digital output, open-collector output; maximum load current: 100 mA; maximum control voltage: 30 V. | ||||
| Digital Output Functions | Freely assignable, including drive ready, drive error, motor in position, motor zero speed, brake control, motor at speed, index-Z signal, maximum-speed limit, shaft lock, at limit and home found. | ||||
| Encoder Output | Two isolated RS485 differential ABZ encoder-signal outputs (one from the encoder used by the drive), 2,500 lines; Encoder 1 is software configurable. | ||||
| Brake | Controlled internally by the drive. LOCK+ and LOCK- may be used for forced brake release only when the drive is disabled. | ||||
| STO | Two STO signals for connection to a safety controller, safety switch or safety sensor; input voltage: 24 VDC ±15%; typical input current: 2.3 mA; IEC 61131-2 Type 1 logic level; input impedance: 10 kΩ. | ||||
| Protection Functions | Drive overtemperature, motor overtemperature, overcurrent, short circuit, I²T, overvoltage and undervoltage | ||||
| RS485 / Modbus | Maximum 115.2 Kbps; supports Modbus RTU | ||||
| CAN Bus | Maximum 1 Mbps; supports CANopen | ||||
| Encoder Type | Magnetic encoder | ||||
| Protection Rating | IP54 | ||||
| Operating Environment | Operating Temperature | 0°C to 40°C | |||
| Storage Temperature | Short-term storage (within 1 month): -20°C to +65°C; long-term storage (over 1 month): -10°C to +55°C. | ||||
| Humidity (Non-condensing) | ≤90% RH | ||||
| Atmospheric Pressure | 67-106 kPa | ||||
| Operating Altitude | Rated operation below 1,000 m. Above 1,000 m, derate by 1.5% for every additional 100 m. Maximum operating altitude: 3,000 m. | ||||