At a Glance
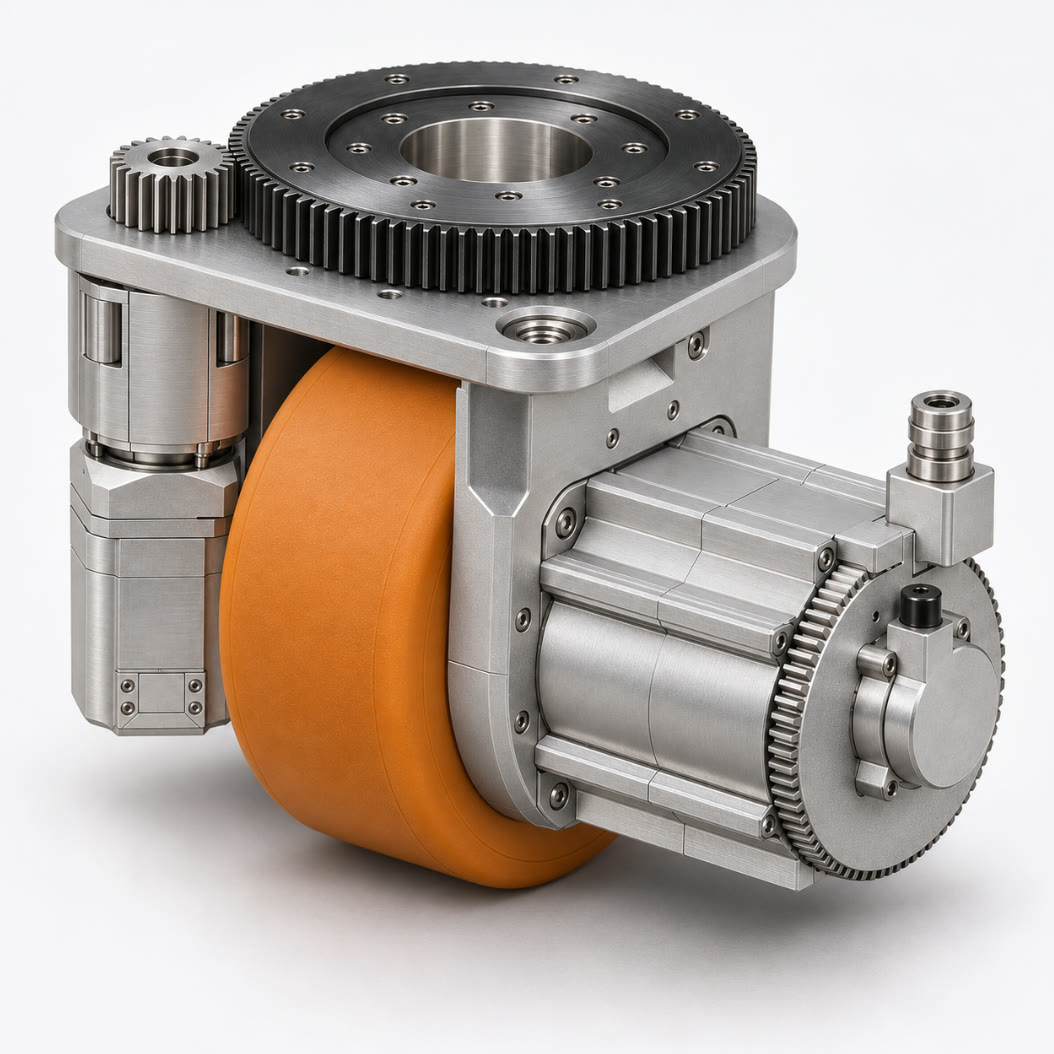
A compact horizontal drive-steering unit: PMSM servo travel and steering motors, planetary reduction and a slewing bearing in one module for AGV and AMR chassis.
| Load per unit | 350–2,000 kg |
|---|---|
| Wheel diameter | Ø125–Ø200 mm |
| Traction power | 0.4–3.0 kW at 48 VDC |
| Travel speed | up to 75 m/min |
| Best for | latent (underride) AMRs, forklift AGVs and material-handling chassis |
| Manufacturer | JY Robot, China (R&D in Nanjing, production in Zhejiang) |
Also consider: heavy-duty series for 1.5–10 t per unit; solid rubber tyres for outdoor lanes and ramps.
Model Pages
Each configuration in this series has its own specification page:
Product Overview
The JYD-HW standard series is a compact horizontal drive-steering platform. Each unit integrates a PMSM traction servo motor, a servo steering motor, planetary reduction and a slewing bearing, so travel, steering and angle feedback come in one module.
Seven standard models cover Ø125–200 mm drive wheels, 350–2,000 kg per unit, 0.4–3.0 kW traction power and travel speeds up to 75 m/min. Typical vehicles are latent (underride) AMRs, forklift AGVs and material-handling chassis.
Motor, gear ratio, tread and control interface can be adapted per project. The steering motor has a built-in encoder, so no external angle encoder is needed; a dual-encoder option supports functional-safety vehicle designs.
Key Features
PMSM servo motors
Servo motors for both travel and steering.Built-in steering encoder
No external angle encoder is needed.Wide power range
Standard 0.4–7.5 kW across the steering-unit range; custom up to 20 kW.Dual encoder option
Supports functional-safety vehicle designs.Product Specifications
| Category | Parameter | JYD-HW125-M400-L350-G16 | JYD-HW150-M750-L500-G20 | JYD-HW160-M750-L800-G20 | JYD-HW180-M1500-L1000-G24 | JYD-HW200-M750-L1000-G50 | JYD-HW200-M1500-L1500-G24 | JYD-HW200-M3000-L2000-G40 |
| Unit | Wheel diameter (mm) | Ø125 | Ø150 | Ø160 | Ø180 | Ø200 | Ø200 | Ø200 |
| Max. load (kg) | 350 | 500 | 800 | 1,000 | 1,000 | 1,500 | 2,000 | |
| Travel speed (m/min) | 74 | 70 | 75 | 72 | 38 | 65 | 47 | |
| Wheel torque rated / max (N·m) | 17 / 34 | 41 / 82 | 40 / 80 | 102 / 204 | 102 / 204 | 122 / 244 | 323 / 646 | |
| Brake torque (N·m) | 4 | 6 | 6 | 16 | 16 | 16 | 16 | |
| Traction | Motor | PMSM servo | ||||||
| Rated power (kW) | 0.4 | 0.75 | 0.75 | 1.5 | 0.75 | 1.5 | 3.0 | |
| Rated voltage (VDC) | 48 | |||||||
| Rated current (A) | 11 | 20 | 23 | 38 | 23 | 39 | 72 | |
| Rated speed (rpm) | 3000 | 3000 | 3000 | 3000 | 3000 | 2500 | 3000 | |
| Rated torque (N·m) | 1.27 | 2.4 | 2.4 | 5 | 2.4 | 6 | 9.5 | |
| Gear ratio | 16 | 20 | 20 | 24 | 50 | 24 | 40 | |
| Steering | Rated power (kW) | 0.1 | 0.2 | 0.1 | 0.2 | 0.4 | 0.4 | 0.4 |
| Rated current (A) | 4 | 5.5 | 4 | 5.5 | 10 | 11 | 11 | |
| Rated torque (N·m) | 0.32 | 0.64 | 0.32 | 0.64 | 1.27 | 1.27 | 1.27 | |
| Final steering ratio | 283.5 | 247.5 | 265.5 | 265.5 | 265 | 315 | 315 | |
| Max. steering speed (°/s) | 63.5 | 72 | 68 | 68 | 68 | 57 | 57 | |
| Steering angle | ±141° | ±120° | ±120° | ±120° | ±110° | ±120° | ±120° | |
| General | Encoder | Incremental / absolute | ||||||